
Physical AI promises robots that can perceive, act and adapt in the physical world with far less task-specific engineering than traditional automation.
It’s a compelling proposition: robots powered by AI models trained on vast amounts of data, capable of improving over time and operating effectively in far less structured environments. But how do we get there?
As AI systems move from the digital to the physical world, new requirements emerge. Intelligent models and policies remain essential, but they are only a part of the equation. Robots ultimately interact with the physical world through grippers, sensors and tools that make direct contact with objects.
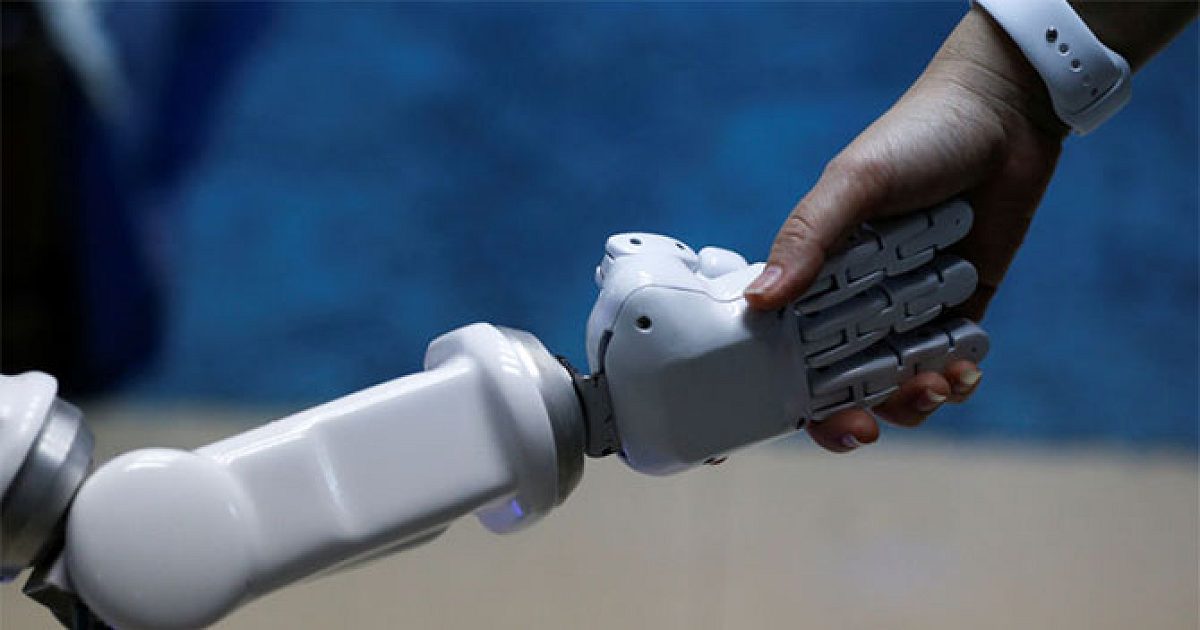
For physical AI to deliver on its promise, it needs a reliable physical interaction layer: End-of-arm tooling (EOAT) that combines adaptability, sensing and feedback so robots can respond effectively to uncertainty and variation.
In selecting the right EOAT for physical AI-driven robotic applications, these four requirements are critical:
1. Ability to accommodate real-world variability
In a real-world manufacturing environment, robots need to handle variation in parts, positioning and operating conditions. Physical AI promises to handle more of this variability with less effort. As advances in multimodal foundation models, world models, robot learning, simulation and other areas make robots increasingly capable, the execution layer grows in importance.
The handling is key here. If the EOAT cannot reliably handle variations in part sizes, shapes, and materials, then the model’s intelligence has limited practical value.
Grippers with adjustable gripping parameters and the flexibility to accommodate different parts and conditions give the system greater freedom to put that intelligence into practice.
2. More capable models require a reliable execution layer
Models can generate actions, but hardware must execute those actions. Models can infer that an object should be picked up, but a physical gripper must make contact, apply the right force, detect whether the object is secure, and respond if something changes. Every single time.
Robot motion is relatively mature compared with real-world manipulation. That’s because manipulation depends on physical variables that cannot be eliminated and cannot be modelled perfectly.
This makes basic execution feedback critical. Grip and part detection can confirm whether an object is present and whether a grasp has been successfully completed, giving the system a direct signal that the intended action actually occurred.
Grippers and tools shape what a robot can do and how it interacts with the physical world. Limited tools mean limited practical capabilities, whereas flexible, feedback-capable tools expand the range of options available to the system.
3. Contact-rich data is needed to complement simulation and vision
Simulation allows teams to train, test, and iterate quickly. Vision helps robots recognize objects, understand scenes, and plan actions. Both are important to physical AI, but neither fully captures what happens when a robot physically interacts with an object.
Reliable manipulation also requires physical feedback. How much force is needed to pick up the item? What are the contact dynamics – including friction, slip and deformation? This type of critical feedback is very difficult to reproduce in simulation only. A grasp that works in simulation may still fail in practice due to the uncertainty and variability of the real world.
And while a camera can locate an object, it cannot always determine what is happening during physical interaction. It may also miss subtle slip, asymmetric contact, insertion resistance, and excessive force.
These limitations make multimodal feedback from EOAT an important part of physical AI. Different forms of sensing provide information at different stages of an interaction: Proximity sensing provides data before the robot makes contact. Force/torque sensing can provide information during contact. Together with grip detection and success or failure signals, this gives the system a richer picture of what is happening during manipulation.
For learning-based systems, receiving this interaction data can vastly improve training, validation, and failure analysis.
4. Physical AI requires flexibility across the tooling layer
Physical AI is often associated with general-purpose robots, but general-purpose does not mean that a single end-effector can perform every type of physical interaction.
Different objects and applications require different modes of interaction:
- 2-finger grippers suit a broad range of handling tasks.
- 3-finger grippers provide auto-centering gripping for cylindrical parts across a wide gripping range.
- Vacuum and magnetic tools provide alternative gripping methods for suitable surfaces and materials.
- Force/torque sensors provide feedback for contact-rich tasks.
- Tool changers allow a robot to switch between end effectors.
In practice, physical AI requires hardware flexibility as well as software flexibility. A broad EOAT portfolio with a unified interface can accommodate different modes of interaction while making it easier for the robot to switch between tools.
Built for a world outside labs and fixed structures
The next phase of physical AI will depend on stronger models, better data, improved simulation, and more capable robot platforms. It will also depend on the physical interaction layer consisting of grippers, sensors, tool changers, and end-of-arm technologies that enable models to act reliably in the real world.
End-of-arm tools are no longer simply the last component to be added to a robot. They are an integral part of advanced learning systems.
Before ‘Physical AI’ became part of the robotics vocabulary, OnRobot was addressing many of the practical challenges that define physical AI research today, including adaptability, sensing, feedback, and the ability to handle real-world variation. The RG2-FT gripper, for example, combines gripping with built-in force/torque and proximity sensing at the fingertips. This feedback supports delicate handling, part hand-offs, insertion, alignment, and manipulation under uncertainty.
OnRobot’s portfolio includes 2-finger grippers, 3-finger grippers, force/torque sensing, vacuum tools, magnetic grippers, tool changers, and other end-of-arm technologies, providing a set of flexible physical interfaces that physical AI researchers and OEMs can apply to a wide range of tasks, objects, and environments. More than 22,000 OnRobot products are deployed worldwide across a wide range of applications.


Leave a Reply